研究问题与核心判断
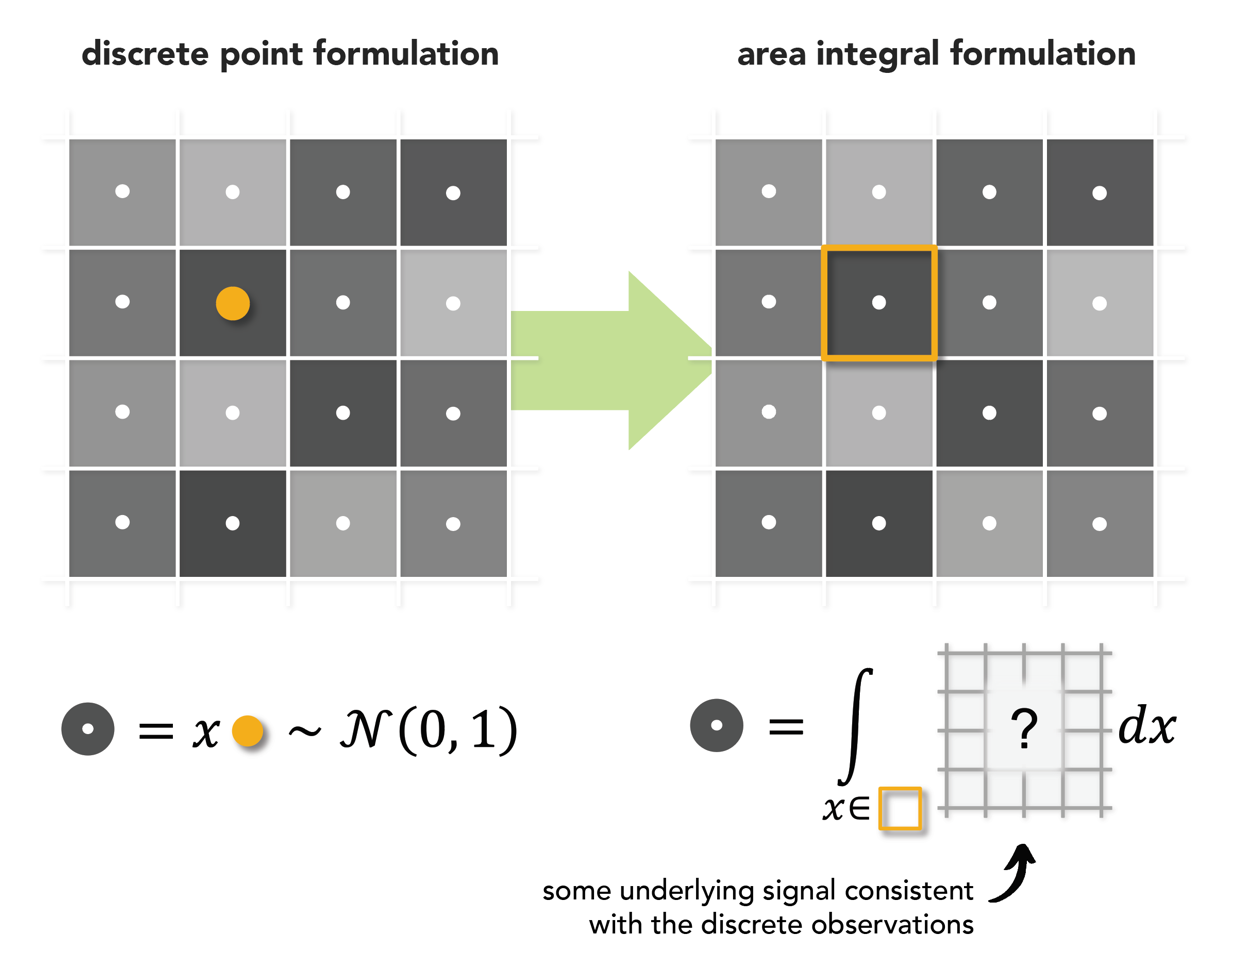
逐帧图像扩散模型在视频上缺少运动相关的噪声先验。独立噪声造成高频细节逐帧变化,固定噪声把细节固定在图像坐标,普通插值会改变方差和空间独立性。论文研究的问题是:给定光流或形变,如何同时保存时间相关、单帧标准高斯分布和像素间独立性。
时间无关
每帧重新采样,逐帧边际正确,跨帧关联被清除,结果容易闪烁。
图像坐标固定
跨帧高度相关,噪声细节未随内容运动,容易出现 texture sticking。
分布被改变
bilinear 与 bicubic 降低方差,nearest 复制样本并引入空间相关。
输入、输出与作用位置
输入
- anchor frame 的离散噪声 \(G_0\in\mathbb{R}^{D\times D}\);
- anchor 到目标帧或相邻帧之间的 deformation / optical flow \(T\);
- 噪声细分层级 \(k\) 与像素轮廓分段数 \(s\);
- 任务条件,例如低分辨率帧、JPEG 帧、人物图像与 pose。
输出
- 每一目标帧的离散噪声 \(G_t\),单帧接近 i.i.d. \(\mathcal{N}(0,1)\);
- 跨帧相关由输入形变决定,运动区域中的噪声随内容移动;
- 该先验进入原 diffusion inference,不需要为 SDEdit、I²SB 或 PIDM 重新训练。
从随机测度到条件细分
白高斯随机测度
在 \(E=[0,D]\times[0,D]\) 上取 Borel σ-algebra \(\mathcal{E}=\mathcal{B}(E)\) 和 Lebesgue 面积测度 \(\nu\)。白噪声 \(W\) 是随机集合函数,有限面积集合 \(A\) 对应:
互不相交集合满足独立性与可加性:
任意两个集合的协方差由交叠面积决定:
第 \(k\) 层把每条边细分为 \(2^k\) 份。线性放大倍数为 \(N=2^k\),子像素总数为 \(N_k=4^k=N^2\),每个子像素面积与方差为 \(1/N_k\)。
给定粗像素的条件高斯
把单位像素 \(A\) 分成 \(N\times N\) 个子块。令 \(X=W(A)=x\),\(\mathbf{Y}\in\mathbb{R}^{N^2}\) 收集子块积分,\(\mathbf{u}\) 为全一向量。联合高斯的条件公式为:
条件协方差在全一方向上的特征值为零。取 \(\mathbf{Z}\sim\mathcal{N}(\mathbf{0},\mathbf{I}_{N^2})\),\(\bar Z=N^{-2}\mathbf{u}^{\mathsf T}\mathbf{Z}\):
将细分噪声乘以线性倍数 \(N\),Algorithm 1 的单位方差版本为:
Table 2:符号定义
分布保持传输与离散算法
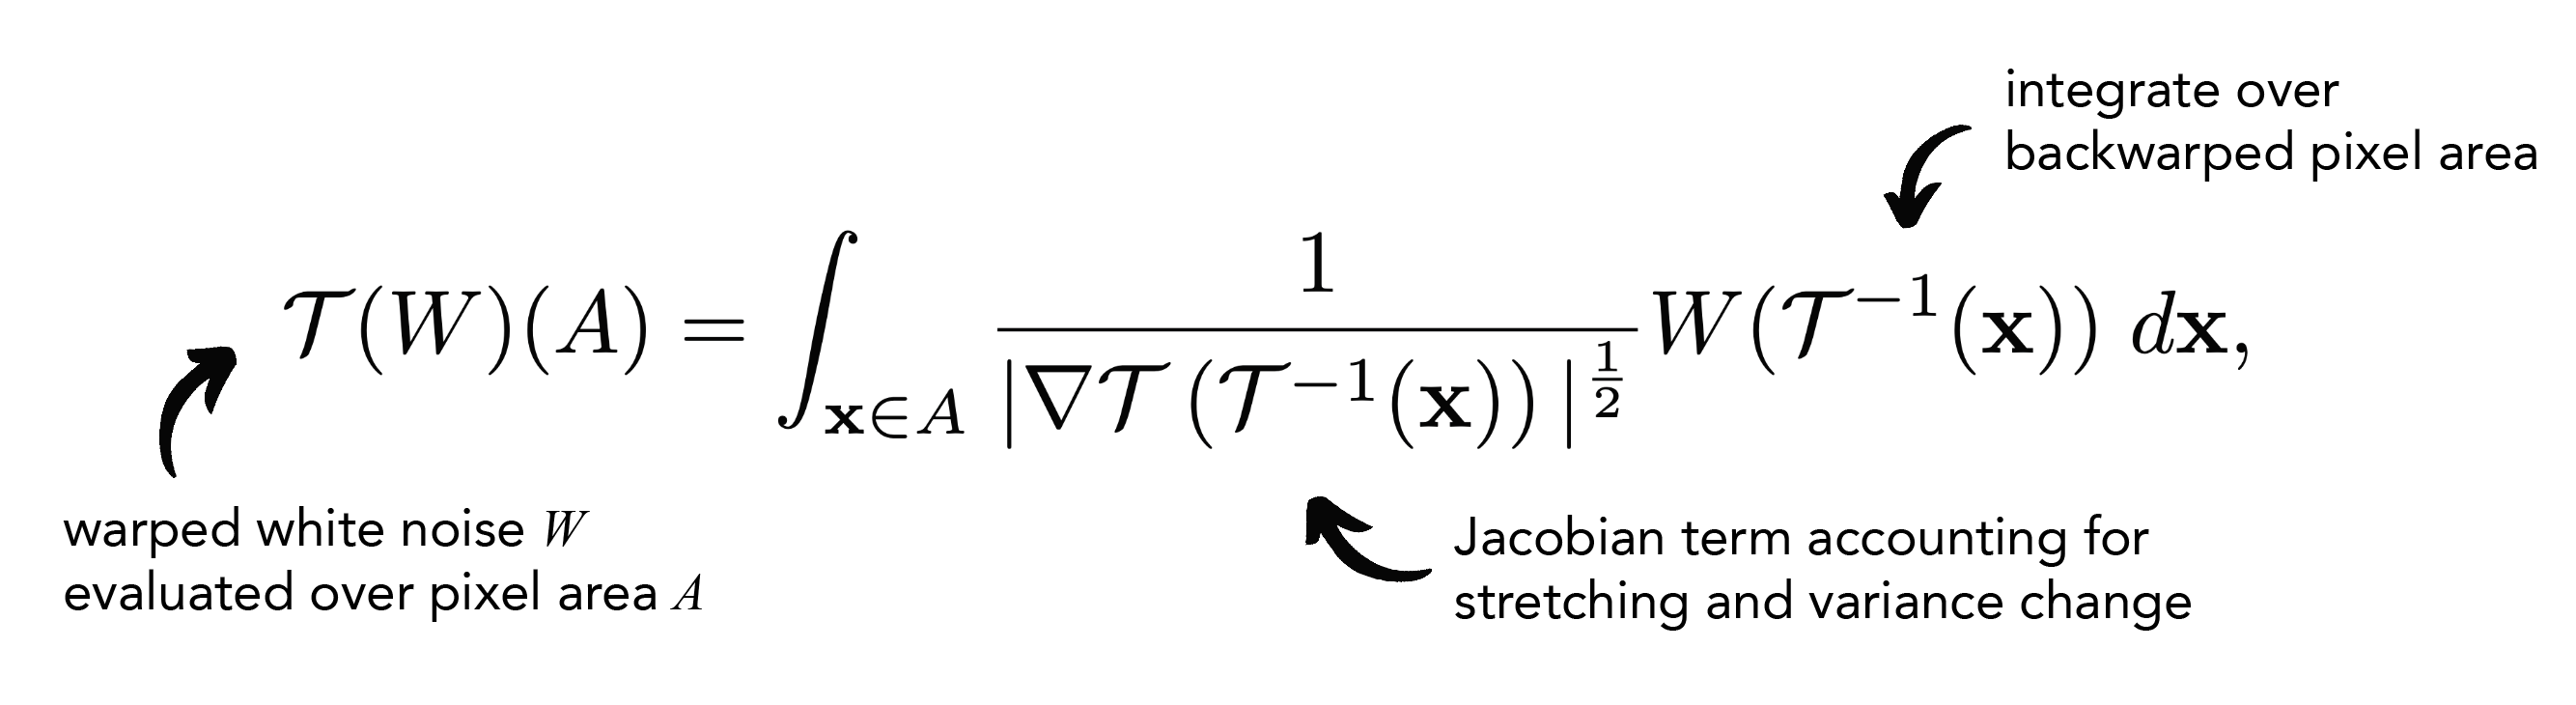
连续传输:Jacobian 平方根
假设 \(T:E\rightarrow E\) 是 diffeomorphism。论文在反向取样时乘以 Jacobian 行列式的负二分之一次方:
这里的 \(W(T^{-1}(x))\,\mathrm{d}x\) 按白噪声分布作用于测试区域理解;附录以 Brownian sheet 的 Itô 积分 \(W(x)\mathrm{d}x=\mathrm{d}B(x)\) 赋予严格含义。令 \(y=T^{-1}(x)\),变量替换和 Itô isometry 给出:
离散近似
对目标像素 \(p\),把轮廓按 \(s\) 细分并三角化,再以 reverse deformation 映射回 anchor。覆盖的第 \(k\) 层子像素集合为 \(\Omega_p\)。令 \(W_k(A_i^k)=\sqrt{N_k}W(A_i^k)\):
平方根归一化确保独立标准高斯之和仍有单位方差。多边形覆盖集合决定跨帧 covariance。
一维 Brownian bridge 解释
线性插值的方差为 \((1-\alpha)^2+\alpha^2\),在区间内部低于 1。积分噪声条件分布为:
stochastic residual 补足缺少的方差;对 \(x_0,x_1\) 积分后得到 \(\operatorname{Var}(z)=1\)。
比较 prior 的实际定义
PYoCo 与 Control-A-Video
PYoCo mixed 将每帧独立噪声与全视频共享噪声线性组合;progressive 以逐帧扰动前一帧噪声的 autoregressive 方式采样。Control-A-Video 在 RGB 时间差超过预定义阈值的位置重新采样,其余位置复用噪声。本文没有公开 PYoCo mixing coefficient、progressive perturbation scale 或 residual threshold 的具体取值。
Root-bilinear
该 baseline 把 bilinear 权重替换为其平方根。若输入高斯样本相互独立,平方权重和恢复为普通 bilinear 权重和,因此能够保持单位方差;连续重复 warping 后输入已相关,该保证失效,Figure 7 显示误差会累积。
实验设置与复现边界
SDEdit · LSUN Bedroom
- 合成卧室 render 逐帧转为真实卧室外观。
- 3 个 scene,每个 scene 的数值为 4 个 variation 均值。
- 分别评估有无 cross-frame attention;主 Table 1 采用带 attention 设置。
- FID 将同一视频全部帧与 LSUN Bedroom 比较,视频内部多样性很低。
I²SB · DAVIS
- 4× super-resolution:bear、blackswan、car turn。
- JPEG restoration:cows、goat、train。
- 从受损输入估计 RAFT optical flow。
- 复用 I²SB checkpoint;完整 sampling 参数没有系统公开。
PIDM · DeepFashion
- 先运行少数 denoising steps 得到粗人物预测。
- 抽取 DensePose,叠加到粗预测,再用 RAFT 估计 optical flow。
- 3 个 quasi-static 输入,并构造 3 个水平 camera-shift 输入。
- 全图 Warp MSE 受静止背景比例影响。
2D fluid super-resolution
- Tang et al. (2021) fluid solver 生成 simulation dataset。
- 训练 pixel-space unconditional diffusion model。
- 数据量、split、optimizer、learning rate、batch size、steps、GPU 与训练时间均未公开。
- 结论主要来自项目视频和 x–t slice。
Table 1:四类任务主结果
| Noise prior | Appearance | Video SR 4× | JPEG | PIDM | ||||
|---|---|---|---|---|---|---|---|---|
| Warp ↓ | FID ↓ | Prec. ↑ | Warp ↓ | LPIPS ↓ | Warp ↓ | LPIPS ↓ | Warp ↓ | |
| Random | 10.00 | 74.75 | 0.719 | 8.91 | 0.192 | 8.28 | 0.163 | 34.22 |
| Fixed | 4.35 | 93.56 | 0.644 | 7.97 | 0.179 | 7.54 | 0.163 | 2.26 |
| PYoCo (mixed) | 7.26 | 81.60 | 0.674 | 8.48 | 0.190 | 7.77 | 0.166 | 20.92 |
| PYoCo (prog.) | 4.90 | 84.63 | 0.667 | 8.10 | 0.190 | 7.48 | 0.163 | 11.97 |
| Control-A-Video | 5.09 | 90.82 | 0.649 | 7.98 | 0.192 | 7.73 | 0.164 | 6.45 |
| Bilinear | 3.15 | 143.24 | 0.201 | 21.47 | 0.590 | 5.26 | 0.431 | 2.13 |
| Bicubic | 4.95 | 149.85 | 0.212 | 13.02 | 0.490 | 5.74 | 0.372 | 2.40 |
| Nearest | 15.10 | 154.73 | 0.344 | 14.30 | 0.329 | 7.91 | 0.213 | 9.21 |
| ∫-noise (ours) | 2.50 | 92.63 | 0.661 | 6.49 | 0.196 | 5.98 | 0.165 | 2.92 |
Warp MSE 单位为 \(10^{-3}\)。Ours 在 appearance 与 SR temporal metric 上领先;JPEG Warp、PIDM Warp、FID、Precision 和 SR LPIPS 由其他 prior 更优。
Appendix Table 3:每帧运行时间
| 方法 | Wall ms | CPU ms |
|---|---|---|
| Random | 0.01 | 0.01 |
| Fixed | 0.01 | 0.01 |
| PYoCo (mixed) | 0.01 | 0.01 |
| PYoCo (prog.) | 0.01 | 0.01 |
| Control-A-Video | 6.08 | 95.46 |
| Bilinear | 5.26 | 76.76 |
| Bicubic | 6.00 | 87.73 |
| Nearest | 5.17 | 75.73 |
| Root-bilinear | 7.66 | 103.78 |
| DDIM Inv. 20 | 853.42 | 2226.6 |
| DDIM Inv. 50 | 2125.5 | 3608.3 |
| ∫-noise \(k=3,s=4\) | 629.01 | 2274.9 |
在指定设备与分辨率上,629.01 ms 对应约 1.59 帧每秒;该结果不能称为实时。
Appendix Table 4:24 帧开销
| 计时 / \(k\) | \(s=1\) | \(s=2\) | \(s=3\) | \(s=4\) |
|---|---|---|---|---|
| CPU \(k=0\) | 21.6 | 21.7 | 23.0 | 26.2 |
| CPU \(k=1\) | 23.6 | 23.5 | 23.8 | 25.1 |
| CPU \(k=2\) | 30.5 | 29.3 | 29.6 | 30.8 |
| CPU \(k=3\) | 58.8 | 55.4 | 55.0 | 53.7 |
| CPU \(k=4\) | 143.8 | 137.5 | 132.4 | 128.2 |
| Wall \(k=0\) | 10.5 | 10.6 | 11.3 | 12.9 |
| Wall \(k=1\) | 10.5 | 10.6 | 10.8 | 11.3 |
| Wall \(k=2\) | 11.2 | 11.3 | 11.5 | 11.9 |
| Wall \(k=3\) | 15.5 | 15.3 | 15.5 | 15.6 |
| Wall \(k=4\) | 29.1 | 29.2 | 28.6 | 28.7 |
CPU time 与 wall time 的单位均为秒;输入为 24 帧、每帧 \(256\times256\)。
Appendix Table 5:SDEdit Warp MSE
| 方法 | 无 cross-frame attention | 有 cross-frame attention | ||||||
|---|---|---|---|---|---|---|---|---|
| S1 | S2 | S3 | mean | S1 | S2 | S3 | mean | |
| Random | 12.85 | 11.82 | 11.21 | 11.96 | 10.02 | 10.23 | 9.74 | 10.00 |
| Fixed | 4.75 | 4.19 | 5.44 | 4.79 | 4.40 | 3.90 | 4.74 | 4.35 |
| PYoCo mixed | 9.25 | 8.28 | 8.44 | 8.65 | 7.67 | 6.79 | 7.31 | 7.26 |
| PYoCo prog. | 6.27 | 5.52 | 6.41 | 6.06 | 5.18 | 4.26 | 5.25 | 4.90 |
| Control-A-Video | 5.13 | 5.48 | 6.08 | 5.56 | 4.65 | 4.71 | 5.91 | 5.09 |
| Bilinear | 3.12 | 3.93 | 8.33 | 5.13 | 2.70 | 1.89 | 4.86 | 3.15 |
| Bicubic | 3.24 | 5.97 | 15.10 | 8.10 | 2.67 | 3.05 | 9.12 | 4.95 |
| Nearest | 13.77 | 28.78 | 46.59 | 29.71 | 5.12 | 13.69 | 26.48 | 15.10 |
| ∫-noise | 3.47 | 2.09 | 3.68 | 3.08 | 2.97 | 1.70 | 2.83 | 2.50 |
Appendix Table 6:SDEdit FID / Precision
| 方法 | 无 attention | 有 attention | ||
|---|---|---|---|---|
| FID | Prec. | FID | Prec. | |
| Random | 61.14 | 0.659 | 74.75 | 0.719 |
| Fixed | 79.32 | 0.622 | 93.56 | 0.644 |
| PYoCo mixed | 65.07 | 0.656 | 81.60 | 0.674 |
| PYoCo prog. | 66.43 | 0.635 | 84.63 | 0.667 |
| Control-A-Video | 75.21 | 0.618 | 90.82 | 0.649 |
| Bilinear | 185.28 | 0.101 | 143.24 | 0.201 |
| Bicubic | 168.86 | 0.118 | 149.85 | 0.212 |
| Nearest | 192.13 | 0.177 | 154.73 | 0.344 |
| ∫-noise | 73.83 | 0.655 | 92.63 | 0.661 |
Appendix Table 7:I²SB Warp MSE
| 方法 | 4× SR | JPEG | ||||||
|---|---|---|---|---|---|---|---|---|
| bear | black. | car | mean | cows | goat | train | mean | |
| Random | 3.98 | 9.57 | 13.17 | 8.91 | 6.71 | 11.36 | 6.78 | 8.28 |
| Fixed | 2.18 | 8.69 | 13.03 | 7.97 | 5.15 | 11.21 | 6.25 | 7.54 |
| PYoCo mixed | 3.09 | 9.28 | 13.08 | 8.48 | 5.84 | 11.12 | 6.35 | 7.77 |
| PYoCo prog. | 2.32 | 9.08 | 12.90 | 8.10 | 5.33 | 11.05 | 6.06 | 7.48 |
| Control-A-Video | 2.24 | 8.88 | 12.82 | 7.98 | 5.73 | 11.16 | 6.31 | 7.73 |
| Bilinear | 9.96 | 25.52 | 28.94 | 21.47 | 2.85 | 8.44 | 4.49 | 5.26 |
| Bicubic | 4.60 | 15.79 | 18.66 | 13.02 | 3.34 | 8.99 | 4.90 | 5.74 |
| Nearest | 2.95 | 17.38 | 22.56 | 14.30 | 5.03 | 11.14 | 7.55 | 7.91 |
| ∫-noise | 1.19 | 6.76 | 11.51 | 6.49 | 4.04 | 8.88 | 5.01 | 5.98 |
Appendix Table 8:I²SB LPIPS
| 方法 | 4× SR | JPEG | ||||||
|---|---|---|---|---|---|---|---|---|
| bear | black. | car | mean | cows | goat | train | mean | |
| Random | 0.242 | 0.179 | 0.154 | 0.192 | 0.157 | 0.201 | 0.131 | 0.163 |
| Fixed | 0.224 | 0.179 | 0.154 | 0.179 | 0.151 | 0.201 | 0.131 | 0.163 |
| PYoCo mixed | 0.242 | 0.180 | 0.149 | 0.190 | 0.156 | 0.207 | 0.136 | 0.166 |
| PYoCo prog. | 0.243 | 0.180 | 0.134 | 0.190 | 0.153 | 0.201 | 0.136 | 0.163 |
| Control-A-Video | 0.240 | 0.179 | 0.149 | 0.192 | 0.156 | 0.205 | 0.132 | 0.164 |
| Bilinear | 0.668 | 0.589 | 0.515 | 0.590 | 0.447 | 0.513 | 0.332 | 0.431 |
| Bicubic | 0.627 | 0.500 | 0.343 | 0.490 | 0.358 | 0.452 | 0.305 | 0.372 |
| Nearest | 0.297 | 0.414 | 0.275 | 0.329 | 0.167 | 0.253 | 0.221 | 0.213 |
| ∫-noise | 0.235 | 0.202 | 0.152 | 0.196 | 0.154 | 0.202 | 0.138 | 0.165 |
Appendix Table 9:PIDM Warp MSE
| 方法 | Quasi-static | High-variation | ||||||
|---|---|---|---|---|---|---|---|---|
| I1 | I2 | I3 | mean | I1 | I2 | I3 | mean | |
| Random | 26.40 | 46.50 | 23.72 | 32.21 | 27.01 | 50.13 | 25.53 | 34.22 |
| Fixed | 2.40 | 3.29 | 3.14 | 2.94 | 1.76 | 2.22 | 2.78 | 2.26 |
| PYoCo mixed | 15.81 | 22.46 | 12.43 | 16.90 | 18.78 | 28.73 | 15.25 | 20.92 |
| PYoCo prog. | 9.73 | 15.11 | 8.28 | 11.04 | 11.92 | 15.06 | 8.91 | 11.97 |
| Control-A-Video | 6.34 | 13.90 | 8.47 | 9.57 | 6.41 | 7.00 | 5.94 | 6.45 |
| Bilinear | 1.77 | 3.00 | 2.87 | 2.55 | 1.83 | 2.30 | 2.28 | 2.13 |
| Bicubic | 3.15 | 4.07 | 4.10 | 3.77 | 2.15 | 2.41 | 2.66 | 2.40 |
| Nearest | 11.69 | 17.83 | 12.73 | 14.08 | 7.21 | 13.21 | 7.20 | 9.21 |
| ∫-noise | 2.54 | 4.58 | 3.52 | 3.55 | 2.42 | 3.03 | 3.29 | 2.92 |
Figure 1–17 阅读地图
官方项目页提供视频与方法图。论文静态 Figure 以编号占位说明,便于回到 PDF 核查。
Appendix E:latent diffusion 限制
作者报告 warped noise 在 latent diffusion 中的增益较小,并给出三个原因。
空间对应不保真
图像时间一致性无法保证 VAE latent 也时间一致,image-space flow 对 latent noise 的传输仅是近似。
细节由 decoder 生成
低分辨率 latent noise 主要控制构图与低频结构,高频细节由 VAE decoder 补充。
VAE reconstruction error
autoencoder 的重建误差会影响时间一致性,独立于 diffusion noise prior。
实验使用两个同心灰色圆盘,每帧向右移动 8 个 image pixels;Stable Diffusion 压缩倍数为 8,手工把 latent 噪声圆盘移动 1 个整数像素。输入作为 ControlNet scribble,并使用固定 pizza prompt。三组设置依次为 ControlNet、加入 cross-frame attention、再注入并 warp 第一帧 layers 4–11 feature maps。
Reviewer Commentary
理论对象准确
把像素改写为随机测度的面积积分,使细分、可加性与 covariance 具有严格定义。
条件采样可实现
均值移除加粗像素注入,无需训练,严格保持 coarse sum。
任务覆盖广
统一覆盖 appearance、restoration、pose generation 与 fluid surrogate rendering。
理想条件受限
光流非双射、重叠 ownership、两阶段补洞与随机填充缺少统一概率模型。
评估规模有限
三段 DAVIS、三个人体输入与三个卧室场景无法覆盖复杂遮挡和长序列。
复现信息缺失
fluid 训练细节、各应用完整 sampling 参数、随机种子和代码仓库未充分公开。
来源与身份核查
- ICLR 2024 OpenReview:会议论文标识
pzElnMrgSD。 - 官方项目页:作者、ICLR 2024 Oral、方法图、任务视频与 DeepFloyd IF 扩展。
- 官方补充页面:root-bilinear、DDIM inversion 与 latent 结果。
- arXiv:2504.03072:2025-04-03 上传,页面标注 Accepted at ICLR 2024 (Oral)。
- 本地论文 PDF:32 页;正文 1–10 页,References 延续至 14 页,Appendix A–E 位于 15–32 页。
论文 PDF 与官方页面均未发现明确通讯作者标记。归档继续把末位作者 Vinicius C. Azevedo 记录为候选,状态为 unverified。